1. Your skeleton, from a photo.

Start from the person, not an average
AI Skeleton Maker builds the skeleton from photos, removing guesswork before the first take.

For the hand, one photo and two palm measurements are enough: the software compares them against 60,000 samples and outputs a hand skeleton with segment lengths.


For the body, a front and a side photo plus two height measurements produce the full-body skeleton. Starting from the person’s real proportions matters: get a forearm wrong by 2 cm and every joint further down the chain inherits the error. For robotics, a measured hand skeleton is also far easier to retarget onto a robot hand’s own joint model than generic mocap data.
2. Map and scale every sensor

Your skeleton, your rules
Add bones, assign any sensor to any segment, and scale each axis on its own.

The mapping editor separates the hardware from the kinematic model. Build any structure you need, from an extra finger to a gorilla, by setting each segment’s length and its angle from its parent. Assign sensors to segments, then scale their data, for example to 85% or 115%, to correct for clothing or soft-tissue movement. Unlike other systems, scaling works per axis in each segment’s own coordinates (forward, up and right), so you can set 50% on one axis and 90% on another.
Example: if a middle-phalanx sensor fails mid-study, reassign that segment to interpolate between its neighbours and keep capturing, with only a small loss of accuracy.

3. Calibration you configure, not guess

Patented calibration jig: US patent, pending in China and the EU
Calibrate the way your study needs
Two poses, one axis, a few seconds. You choose the reference sensor, axis and direction to suit any glove, suit or setup.

Pick any sensor in the system as the reference and a rotation axis (roll or pitch), then record pose one at rest and pose two at the end of the movement. Body and fingers calibrate separately for higher accuracy. For hands, the patented calibration jig (US patent; pending in China and the EU) holds the fingers in a repeatable posture, with a two-axis bubble level to set the pose. If the skeleton photo is taken in the jig too, the model and the real hand start from exactly the same position.
4. More than the hand

A hand that belongs to an arm
The glove can be a child of an arm or trunk in one skeleton. Glove-only systems stop at the wrist.

Add arm or trunk sensors, props, and HTC Vive trackers to the same skeleton. Vive is native to the software: trackers and controllers are defined in the skeleton file, so a tracker on the back of the hand gives its position in space while the IMUs give every joint’s rotation.
From hand to arm and chest,
in one skeleton

5. Raw data when you need it

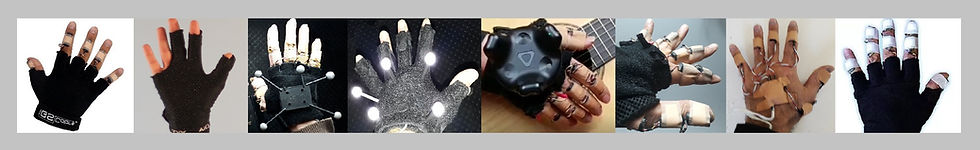
The same electronics: taped on for raw data, or in the glove for comfort
Open fingertips, or no glove at all
Wear the glove for comfort, or tape sensors straight onto the skin for the purest data.

All G6 gloves leave the fingertips free, so the wearer can touch and feel real objects (even when they are taped).
For the most accurate data, researchers tape each sensor directly onto the phalanx. One set of electronics moves between four glove sizes, or from left to right, in about five minutes.
6. Sync and scale

One G6 sensor board: 11 × 16 × 3 mm, under 1 g, linked to the sensors on either side by its UP and DOWN connectors
150 sensors, one PC, zero dropped frames
Seven suits streaming together at 60 FPS.

Gloves and optical markers in one hybrid capture
Every file is timestamped automatically. With OptiTrack, our Motive plugin records the glove and suit data directly inside Motive, alongside the optical markers, for the tightest real-time sync. For Vicon and other optical systems, a UDP start/stop trigger starts and stops both captures together. The open C++ SDK gives direct access to the live data stream, and a ROS2 wrapper is now in beta for robotics teams. [Ask about the ROS2 beta]